Autonomous Design of Uncertainty-Aware Gripper Finger Using Skin Model Shapes
June 1, 2026· ,·
0 min read
Dominik Koch
Equal contribution
,Sven Wimmer
Equal contribution
Jan Baumgärtner
Equal contribution
,Martin Benfer
Gisela Lanza
Abstract
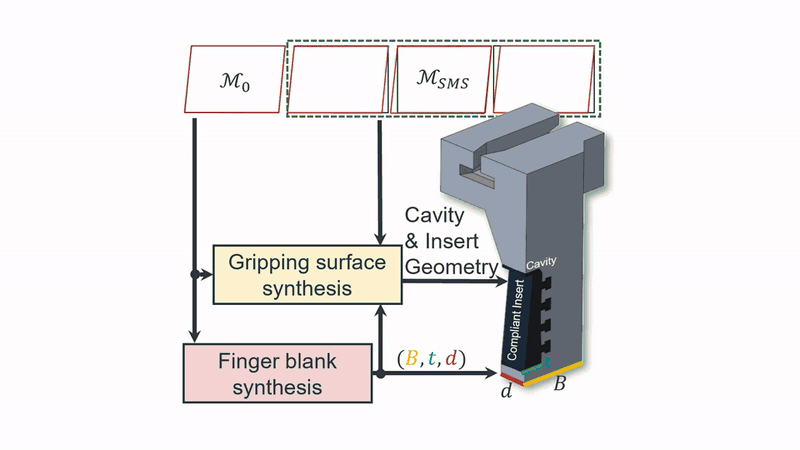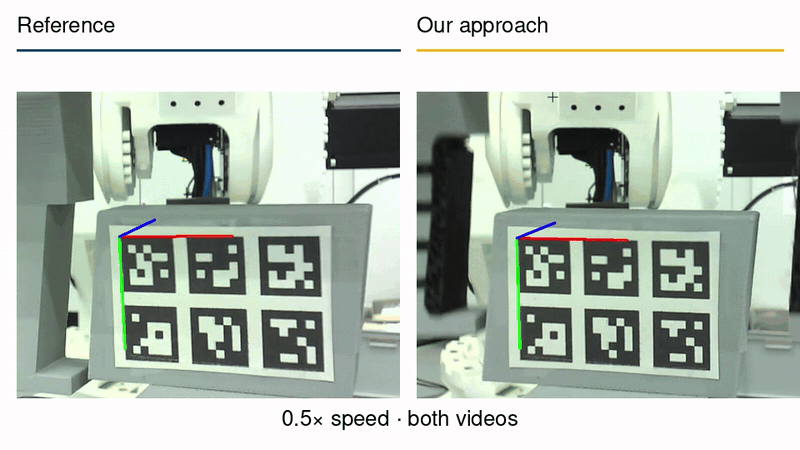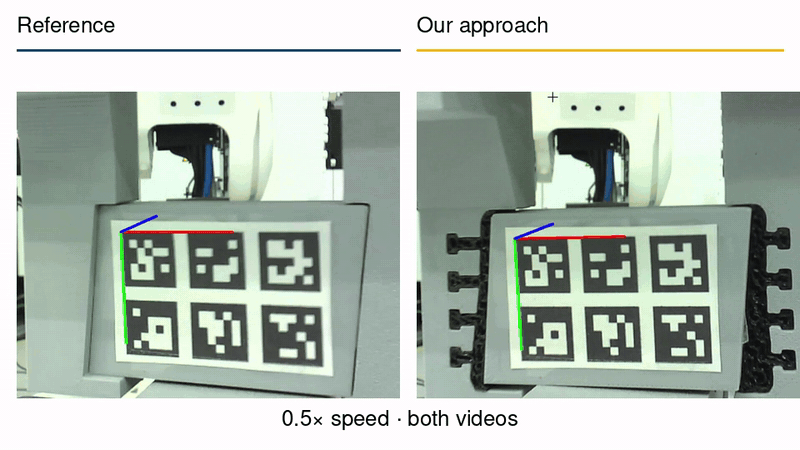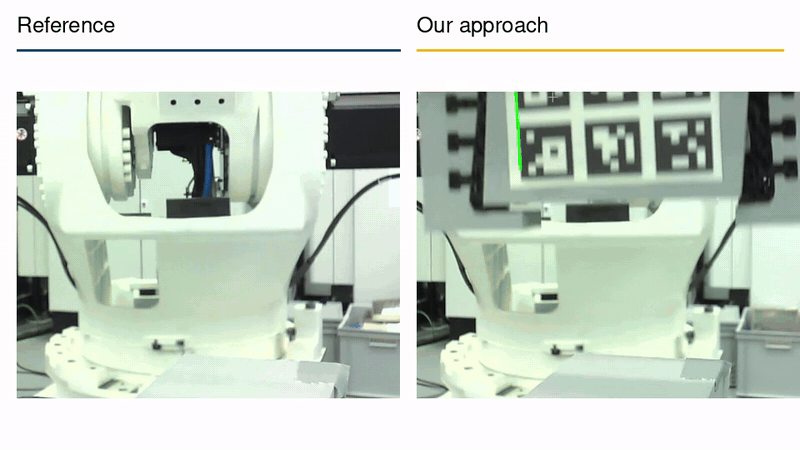
Robust grasping with parallel gripper fingers is often limited by part-to-part geometric variability and uncertainties in object pose, making conventional gripper finger design time-consuming and sensitive to deviations from the nominal shape. This paper presents an uncertainty-aware workflow for automated synthesis of two-finger grippers that integrates Skin Model Shapes as conservative envelopes of end-of-life object realizations in circular production. Candidate finger configurations are parameterized by finger width and immersion depth and evaluated by an algorithm that accounts not only for contact area but also for the resulting forces, while ensuring that the grasp remains feasible within the gripper’s stroke and collision limits. The resulting design is instantiated as a two-part finger set comprising a rigid base finger with an undercut-free, from Skin Model Shape derived contact cavity and a replaceable compliant insert, locally refined on the nominal model. The method is evaluated in an industrial robot cell using repeated grasp-and-lift trials on one nominal part and three deliberately modified variants, applying systematic pose perturbations. Object pose is tracked after gripper closure and after a standardized motion sequence, and performance is benchmarked against a nominal-cut rigid baseline and standard/universal fingers. The results demonstrate manufacturable output generation and reduced post-motion rotational pose drift for the proposed design across the considered variants, while also indicating geometry-dependent failure cases that motivate extensions of the uncertainty bounds and contact-surface synthesis.
Type
Publication
In Procedia CIRP 145 (19th CIRP Conference on Computer-Aided Tolerancing, CAT 2026), pp. 85-90

Authors
Head of Research Industrial Robotics & Scientific Coordinator of CRC 1574
Hi I am Jan! I am a researcher working at the intersection of robotics and manufacturing. My work focuses on intelligent robotic manufacturing systems, where reconfigurable hardware and autonomous reasoning systems meet to enable autonomous and circular production. I also coordinate the Industrial Robotics research at wbk Institute of Production Science, KIT, as well as the Collaborative Research Centre 1574 Circular Factory for the Perpetual Innovative Product.